Varun Burde
I'm a Ph.D. candidate at the Czech Technical University in Prague, advised by Torsten Sattler and Pavel Burget, and a researcher at the Testbed for Industry 4.0 at CIIRC. I'm currently a visiting Ph.D. student at the University of Cambridge, where I'm grateful to be hosted by Dr. Olaf Wysocki in the Computer Vision for Digital Twins group. Before that, I was fortunate to spend six months at ETH Zürich working with Dr. Xi Wang and Prof. Marc Pollefeys in the Computer Vision and Geometry Group.
Before my Ph.D., I did my M.Sc. in Cybernetics and Robotics at CTU, with a master's thesis on deep neural networks for city mapping using Google Street View data. I received the RICAIP Young Investigator Award in 2022. I'm always happy to hear about research collaborations.
Research
I'm interested in 3D computer vision and robotic manipulation: object-centric 3D reconstruction, 6D object pose estimation, and neural scene representations, including for transparent and textureless objects. Representative papers are highlighted.
-
Benchmarking the Effects of Object Pose Estimation and Reconstruction on Robotic Grasping Success
ICRA 2026
arXiv / project page / code / PerceptPick dataset
A benchmark that ties the quality of 3D reconstruction and 6D pose estimation to what matters downstream: whether a real robot's grasp succeeds.
-
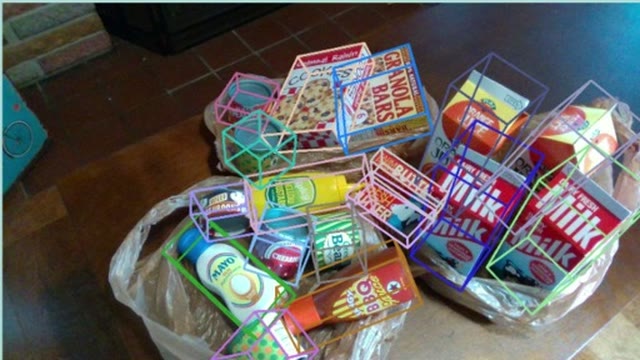 OPFormer: Object Pose Estimation Leveraging Foundation Model with Geometric Encoding
WACV 2026
Object pose estimation that combines features from a vision foundation model with a geometric encoding of the object.
-
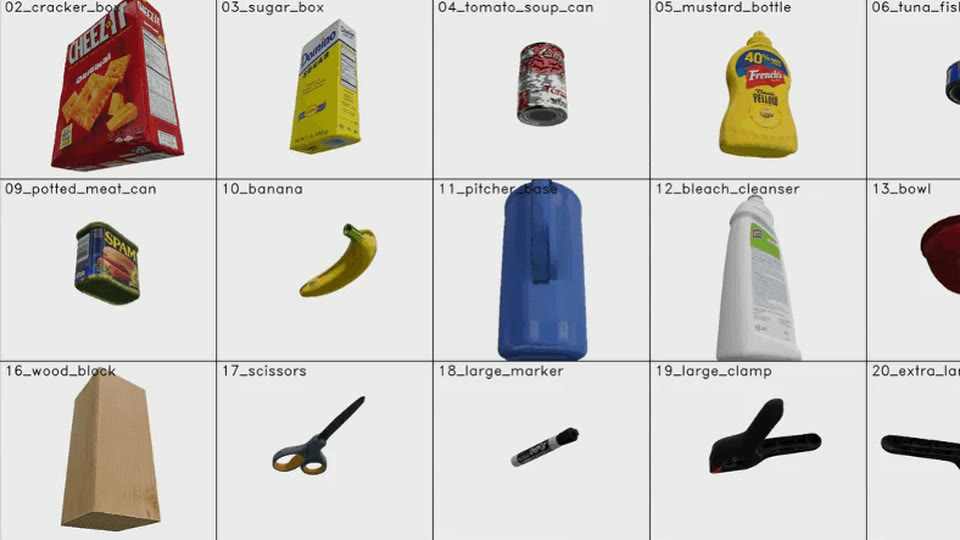 Comparative Evaluation of 3D Reconstruction Methods for Object Pose Estimation
WACV 2025
arXiv / project page / code
Which 3D reconstruction method should you use to build object models for pose estimation? A systematic comparison on the downstream task.
-
Object Pose Estimation Using Implicit Representation for Transparent Objects
ECCV-W 2024 (Spotlight)
arXiv / Transparent-BOP data / fine-tuning data
Implicit object representations for 6D pose estimation of transparent objects, which break most methods. Datasets released.
-
A CAD Model-Based Navigation Method for UAVs around Transmission Tower
CASE 2024
Using the tower's CAD model to localize and navigate a UAV around power transmission towers.
-
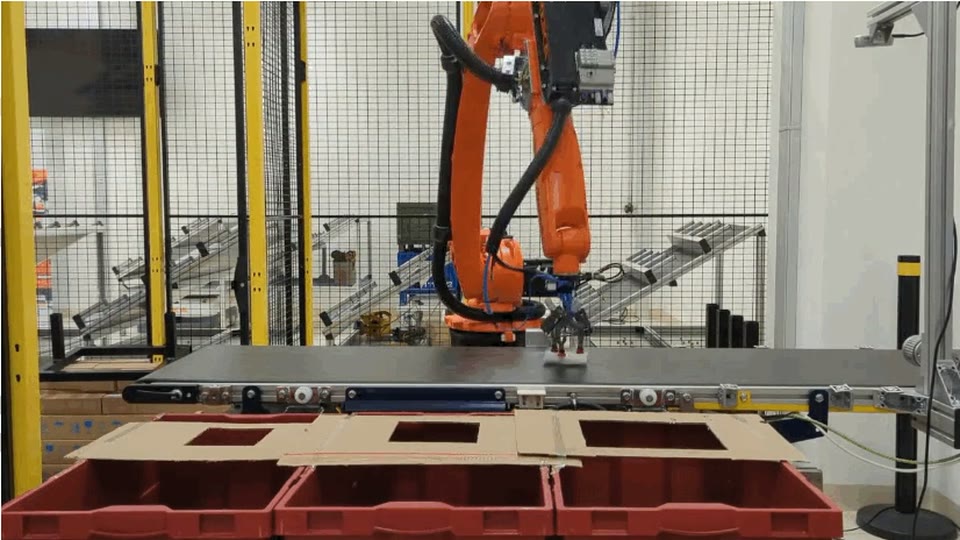 Automatic Workspace Calibration Using Homography for Pick and Place
CASE 2023
Automatic workspace calibration with a homography, replacing tedious camera-robot calibration in pick-and-place setups.
News
- Sep 2026Started a visiting Ph.D. stay at the University of Cambridge, hosted by Dr. Olaf Wysocki in the Computer Vision for Digital Twins group.
- Mar 2026Started a visiting Ph.D. stay at ETH Zürich in the Computer Vision and Geometry Group, hosted by Prof. Marc Pollefeys and Dr. Xi Wang.
- Feb 2026Our ICRA 2026 paper on how perception quality affects grasping is out, with code and the PerceptPick dataset.
- Nov 2025OPFormer, object pose estimation with foundation-model features, is out (WACV 2026).
- Oct 2024Our paper on pose estimation for transparent objects was a spotlight at the ECCV 2024 TRICKY workshop.
- Aug 2024Chaired the Optimized UAV Systems session at IEEE CASE 2024 in Bari and presented our UAV navigation paper.
- Aug 2024Our WACV 2025 paper comparing 3D reconstruction methods for pose estimation is out.
- Aug 2023Presented automatic workspace calibration at IEEE CASE 2023 in Auckland.
- Sep 2021Started my Ph.D. at CTU Prague with Torsten Sattler and Pavel Burget.
Experience
-
Sep 2026 – Mar 2027
Visiting Ph.D. Student · University of Cambridge, United Kingdom
Hosted by Dr. Olaf Wysocki in the Computer Vision for Digital Twins (CV4DT) group. Minimal viable 3D representations for robotic object manipulation.
-
Mar 2026 – Sep 2026
Visiting Ph.D. Student · ETH Zürich, Switzerland
Hosted by Prof. Marc Pollefeys and Dr. Xi Wang in the Computer Vision and Geometry Group (CVG). 3D lifting of objects from egocentric video.
-
Sep 2021 – Present
Doctoral Researcher · CIIRC, Testbed for Industry 4.0, Prague
Developed 3D reconstruction and 6D pose estimation pipelines for industrial pick-and-place under real-world conditions, including transparent and textureless objects. Designed benchmarks linking perception quality to downstream robotic grasping success.
-
Oct 2019 – Aug 2021
Graduate Student Researcher · CIIRC, CMP, Prague
Built SLAM and path-planning systems for autonomous indoor robots, including a GUI-based navigation interface deployed on real hardware.
Education
-
2021 – Present
Ph.D., Computer Science · Czech Technical University in Prague
Thesis: 3D Reconstruction for Object Manipulation
-
2020
M.Sc., Cybernetics and Robotics · Czech Technical University in Prague
Thesis: Deep Neural Network for City Mapping Using Google Street View Data
-
2017
B.E., Electronics · Acropolis Technical Campus, Indore, India
Service & Awards
- Reviewer for NeurIPS, ECCV, ICRA, IROS, IEEE CASE, IEEE Transactions on Robotics (T-RO)
- Session Chair, Optimized UAV Systems — IEEE CASE, 2024
- RICAIP Young Investigator Award, 2022
Mentoring
Master's theses supervised at CTU Prague.